Projects
From UAV perching to ambient HRI, these projects span the full stack of a robotics system — sensing, estimation, control, and the humans who use them.
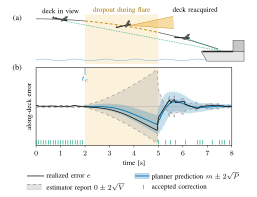
Control Through Planner-Conditioned Estimator Error
Belief-space planning for VTOL ship-deck landing
A planner can predict parts of an estimator's error using information the estimator does not receive. This work accounts for that predictable error and intermittent corrections when planning VTOL landings on a moving ship deck.
View project: Control Through Planner-Conditioned Estimator Error
Robotic Forests
Plant-inspired robot design metaphors for ambient HRI
From a mobile houseplant that expresses emotion to a pill plant that reminds you to take your medicine, I designed, built, and deployed charming robotic plant helpers to make day-to-day tasks easier.
View project: Robotic Forests
Acetabular Cup Extractor
Mechanical Engineering Senior Design Project
When hip replacements need to be replaced, they must be surgically extracted from the bone using a tool called an acetabular cup extractor. Our group designed, built, and tested a patent-pending, powered cup extractor as our undergraduate capstone, winning the WSE Dean's award for best mechanical engineering capstone project, and the Department of Mechanical Engineering's award for best capstone presentation.
View project: Acetabular Cup ExtractorMore Projects

FlyVuer
A modular enclosure for real-time fruit fly monitoring and analysis
Doubling monitoring capacity and providing real-time streaming and analysis capabilities, I designed and built a novel, open-source fruit fly monitoring enclosure harnessing the power of PoE technology and 25 Raspberry Pis.
View project: FlyVuer